Skip to content

HYPER AIFORCE

Technology

AI perception, autonomous patrol, ultra-range teleoperation and robotic motion control.

Technology
On this page

Core Capability · Autonomous Navigation

Autonomous Perception and Navigation Across Complex Environments
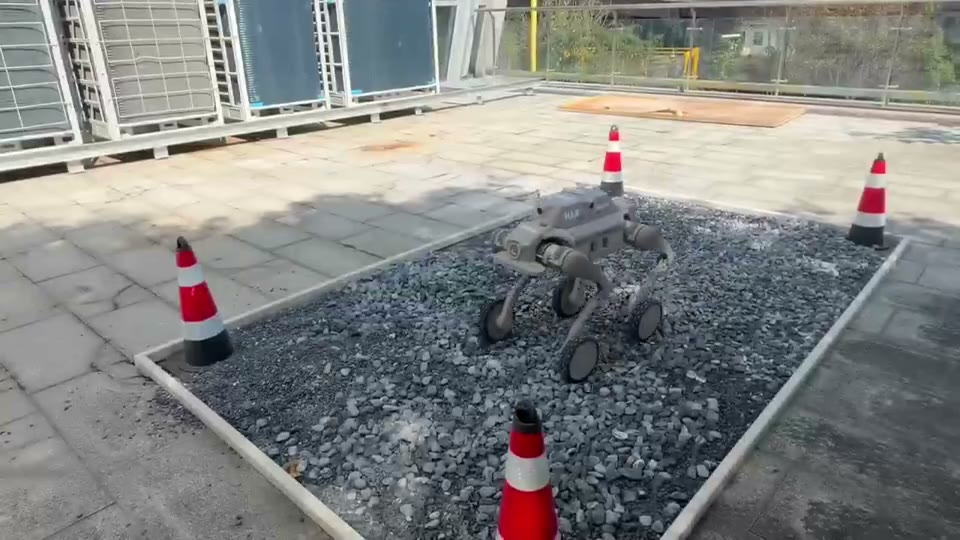
Robot conducting an inspection at a logistics facility

Autonomous Inspection in Complex Environments

Autonomous navigation combines multimodal perception, real-time localization, intelligent path planning, and dynamic obstacle avoidance to enable autonomous inspection and continuous operation in complex environments.

  • Multimodal Perception
  • Real-Time Localization
  • Intelligent Path Planning
  • Dynamic Obstacle Avoidance

Core Capability · Ultra-range Teleoperation

Ultra-range Teleoperation Beyond Line of Sight

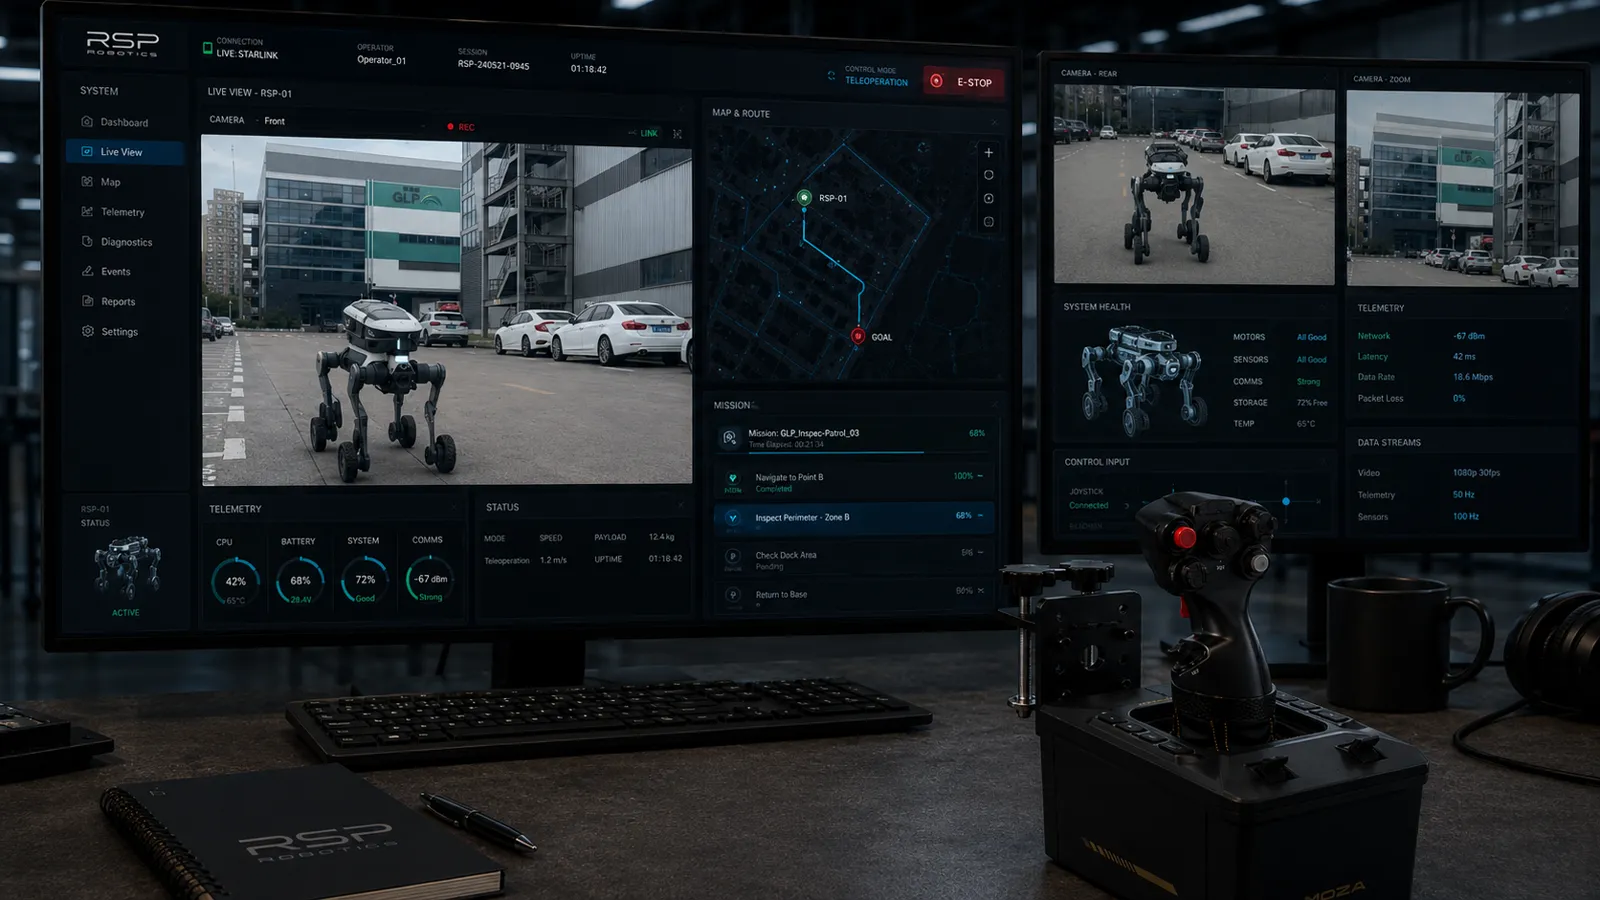
Remote ultra-range teleoperation workstation

Ultra-range Teleoperation Workstation

Ultra-range teleoperation connects operators with robots across distant sites for BVLOS (Beyond Visual Line of Sight) operation. Live video and motion control support human intervention when judgment is needed. Operating distance and latency depend on network coverage, link quality and deployment configuration.

  • Robot Access Across Distant Sites
  • Low-Latency Video and Control
  • Seamless Manual Handover
  • Rapid Exception Response

Software Platform · RSP (Robot Scheduling Platform)

Unified Robot Operations and Scalable Fleet Orchestration

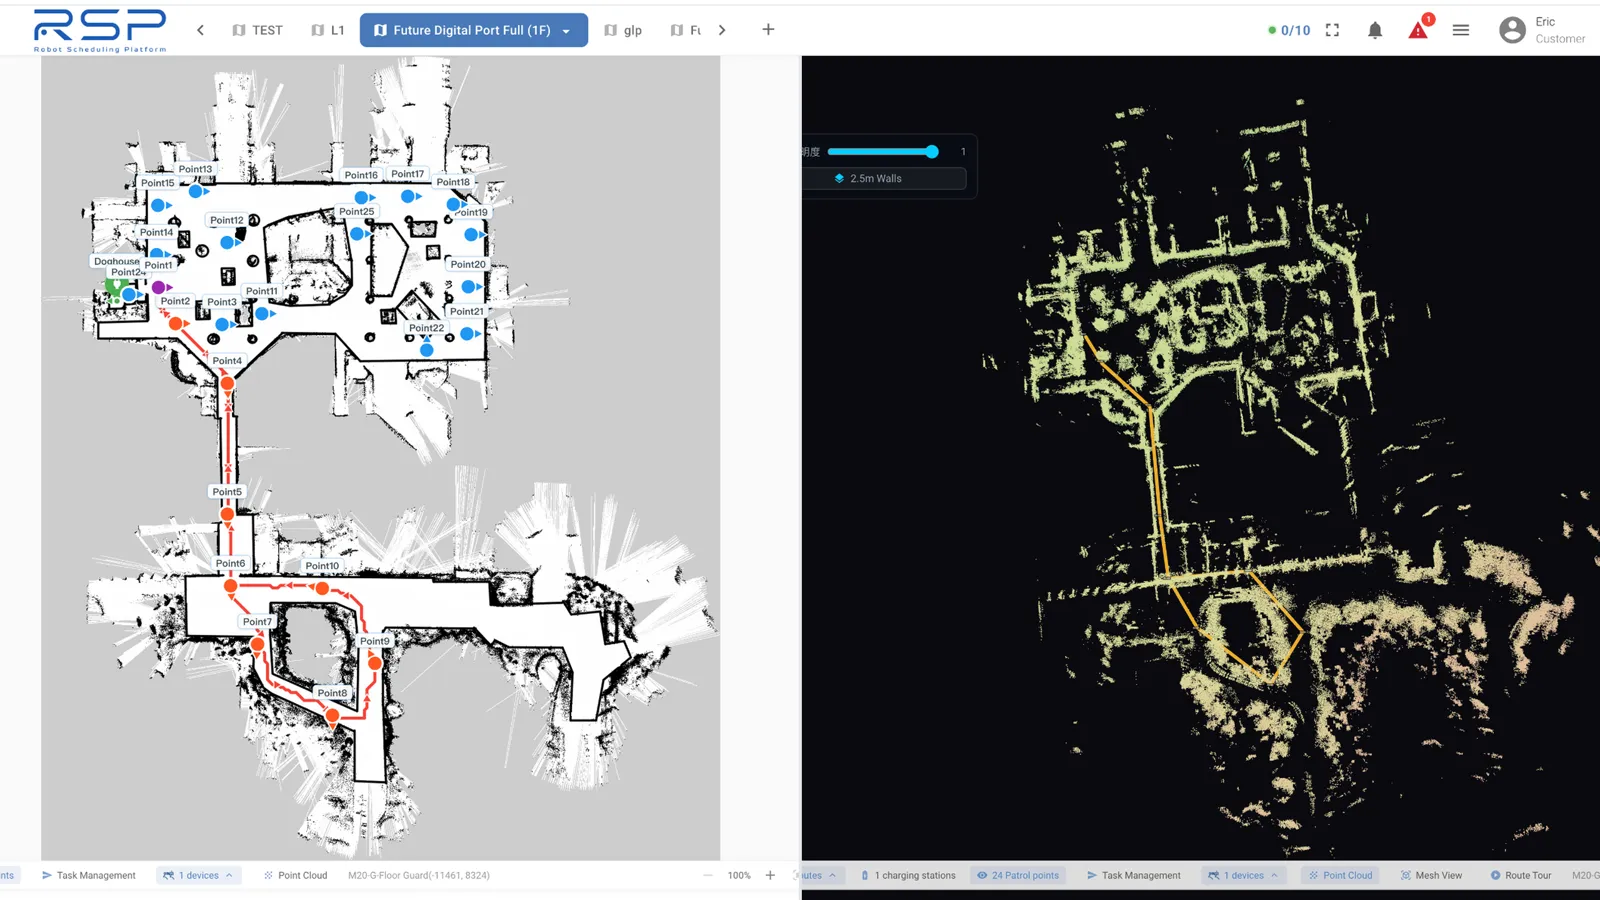
RSP robot operations platform interface

Robot Scheduling Platform

RSP unifies robots, charging infrastructure, perception devices, and business systems in one platform, enabling centralized mission orchestration, fleet monitoring, and inspection data management across multi-robot operations.

  • Robot and System Integration
  • Map and Mission Management
  • Multi-Robot Scheduling and Dispatch
  • Fleet Monitoring and Data Management

Core Capability · Modular Payloads

Flexible Payload Integration for Expanded Sensing Capabilities

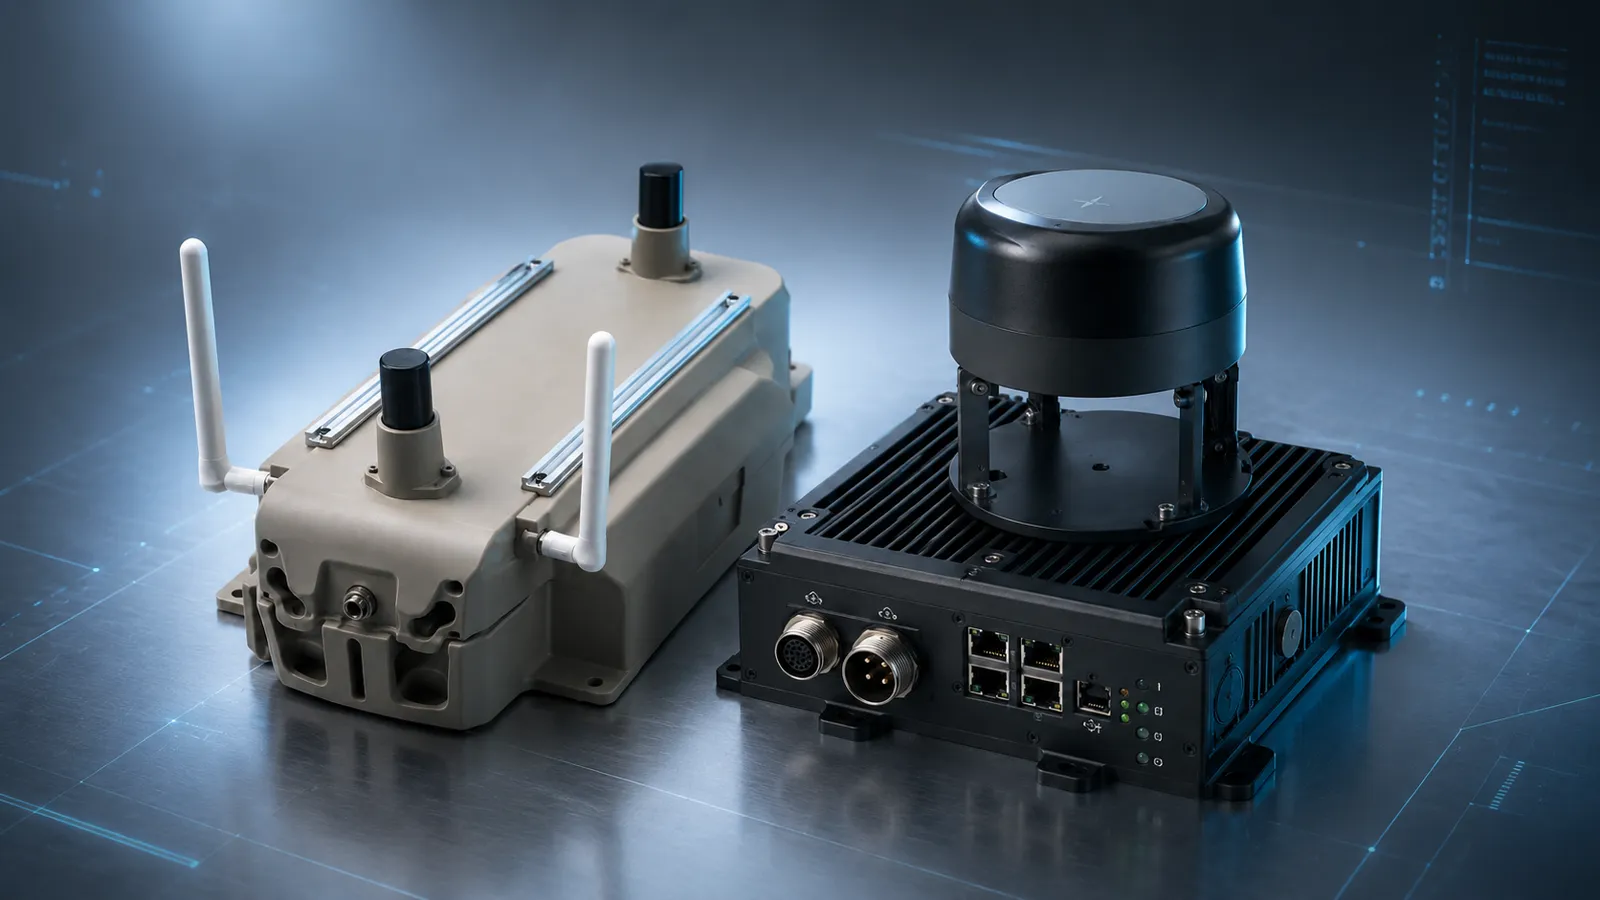
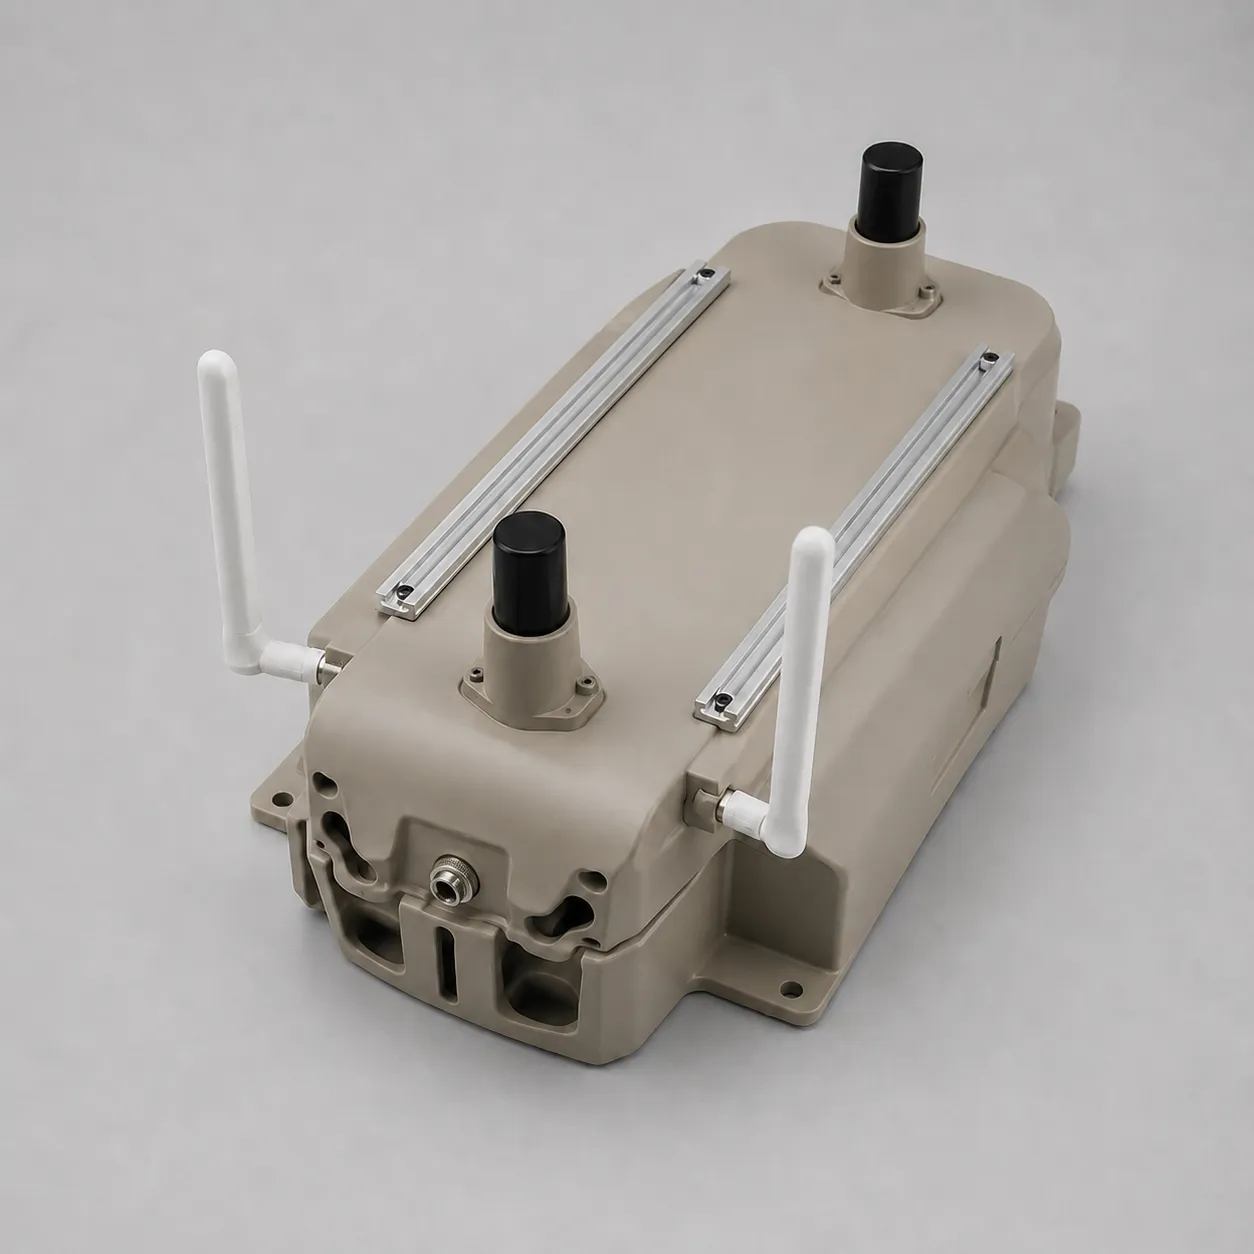
Hardware backpack and sensor payloads

Modular Backpack and Sensor Payloads

The modular backpack supports flexible integration of sensors and mission payloads for different inspection scenarios, enabling reliable data acquisition, real-time transmission, and seamless platform connectivity.

  • Modular Payload Integration
  • Multi-Sensor Compatibility
  • Scenario-Based Configuration
  • Data Collection and Platform Sync

Technology / 01

An integrated operating architecture.

Mobility, perception, communication and control form the technical basis of a robotic deployment. Each layer must be considered within the operating environment.

PROJECT CONSIDERATIONS
Technology
HYPER AIFORCETechnology

PROJECT CONSIDERATIONS

01

Perception and site context

Identify the observations required for the task, from visual inspection to additional sensing. Sensor selection follows the environment and inspection objectives.

02

Connectivity and supervision

Assess network coverage and ultra-range teleoperation for BVLOS (Beyond Visual Line of Sight) operation across distant sites. Establish how teams monitor missions and intervene when conditions change.

03

Integration and validation

Review interfaces with existing systems, data requirements and acceptance criteria. Validate the selected configuration against representative site tasks.

Perception and site context
Connectivity and supervision
Integration and validation
RSP

Necessary storage remembers your choice. Optional Google Analytics helps us understand website use and loads only with your consent.

Necessary storage (always on)

Privacy Policy