01 / FORCE 01
Understand the scene before entering
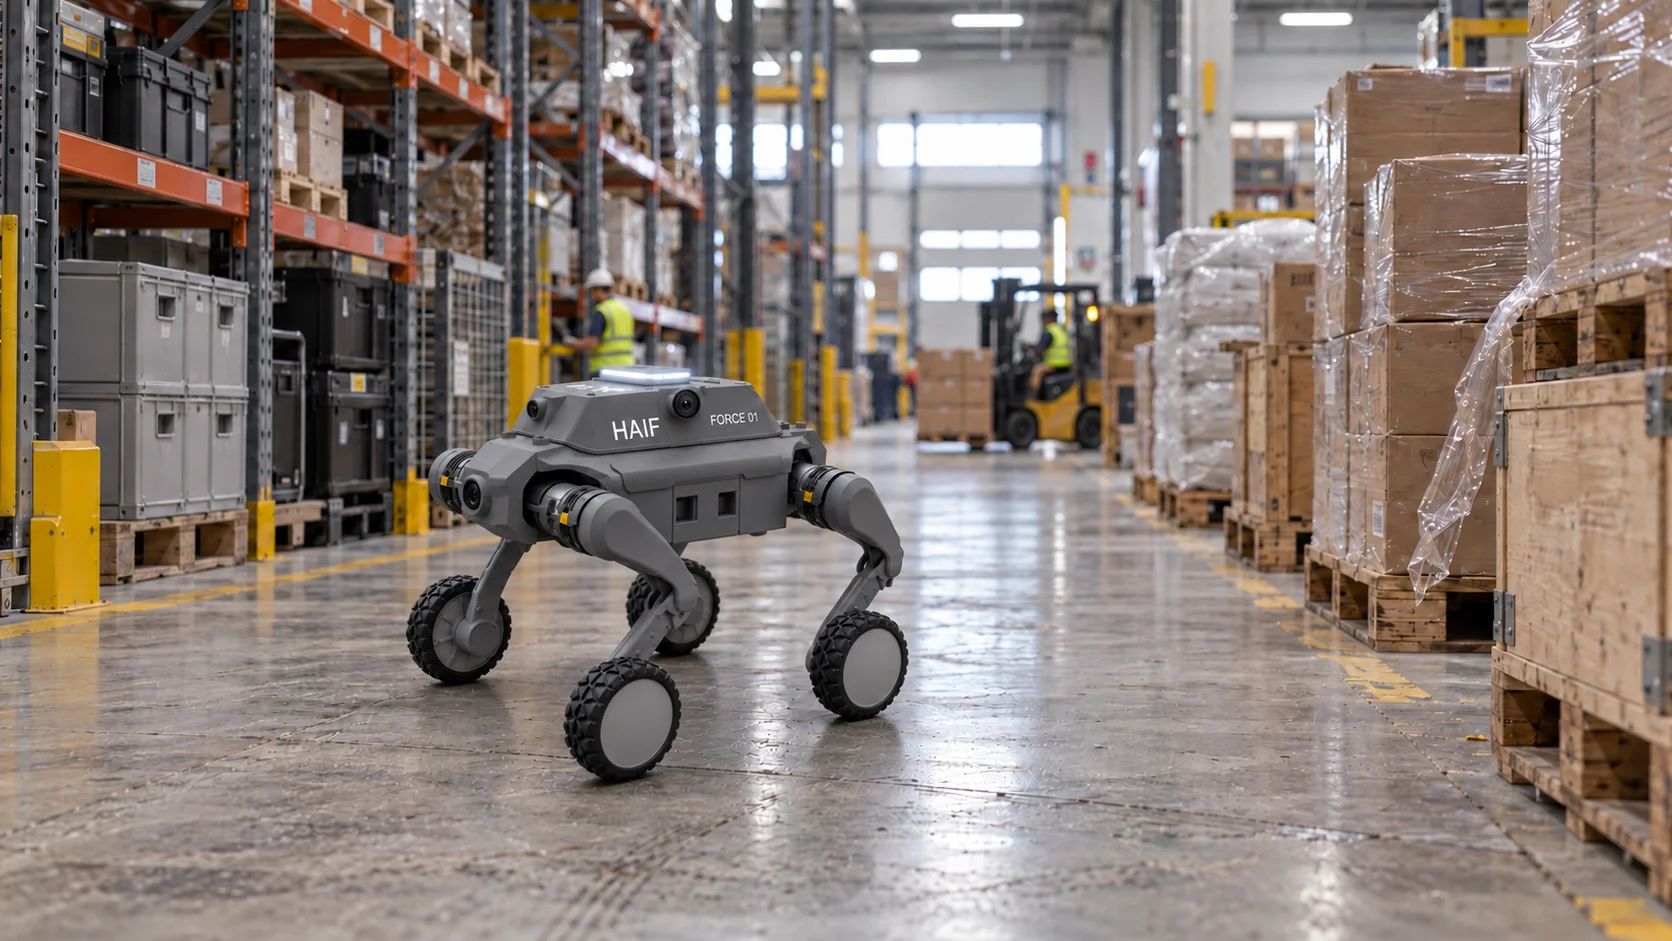
Four low-light cameras provide views around the robot, helping operators check blind spots and confirm changing conditions.
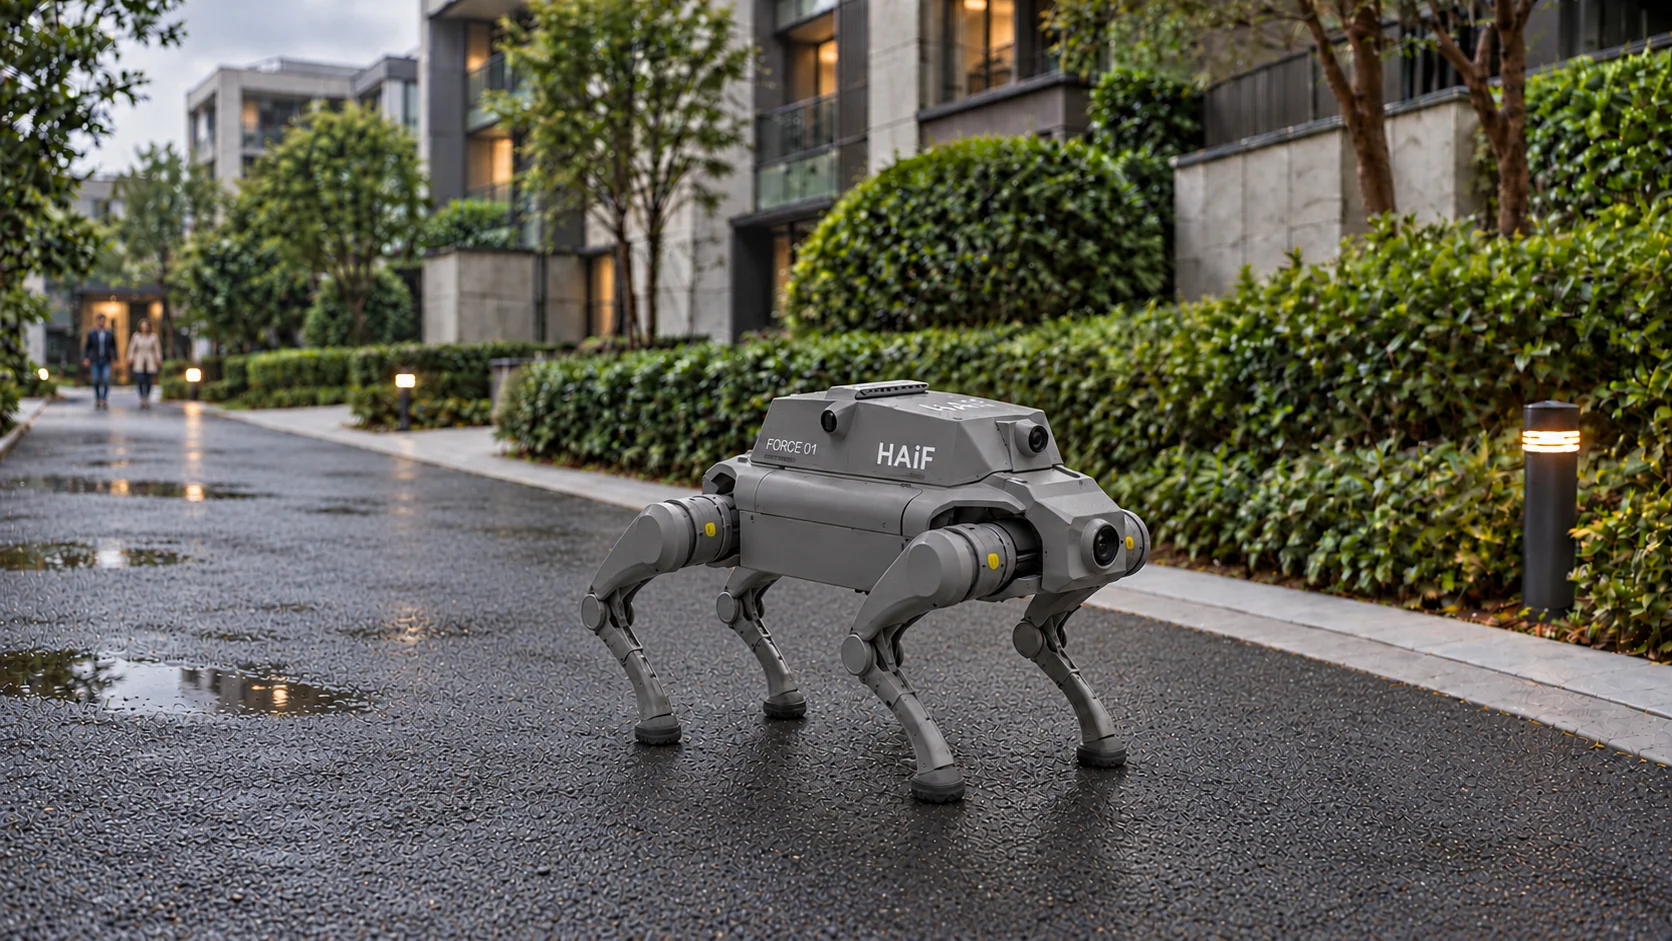
Panoramic Ultra-range Teleoperation Robot
A legged or wheeled-leg robot with an integrated panoramic backpack for ultra-range teleoperation. Operate across distant sites beyond visual line of sight (BVLOS), using live video and motion control. Operating distance depends on network coverage and configuration.
01 / FORCE 01
Four low-light cameras provide views around the robot, helping operators check blind spots and confirm changing conditions.
02 / FORCE 01
Live video and ultra-range teleoperation let operators at distant sites move the robot closer, change viewpoint and inspect without repeated site visits.
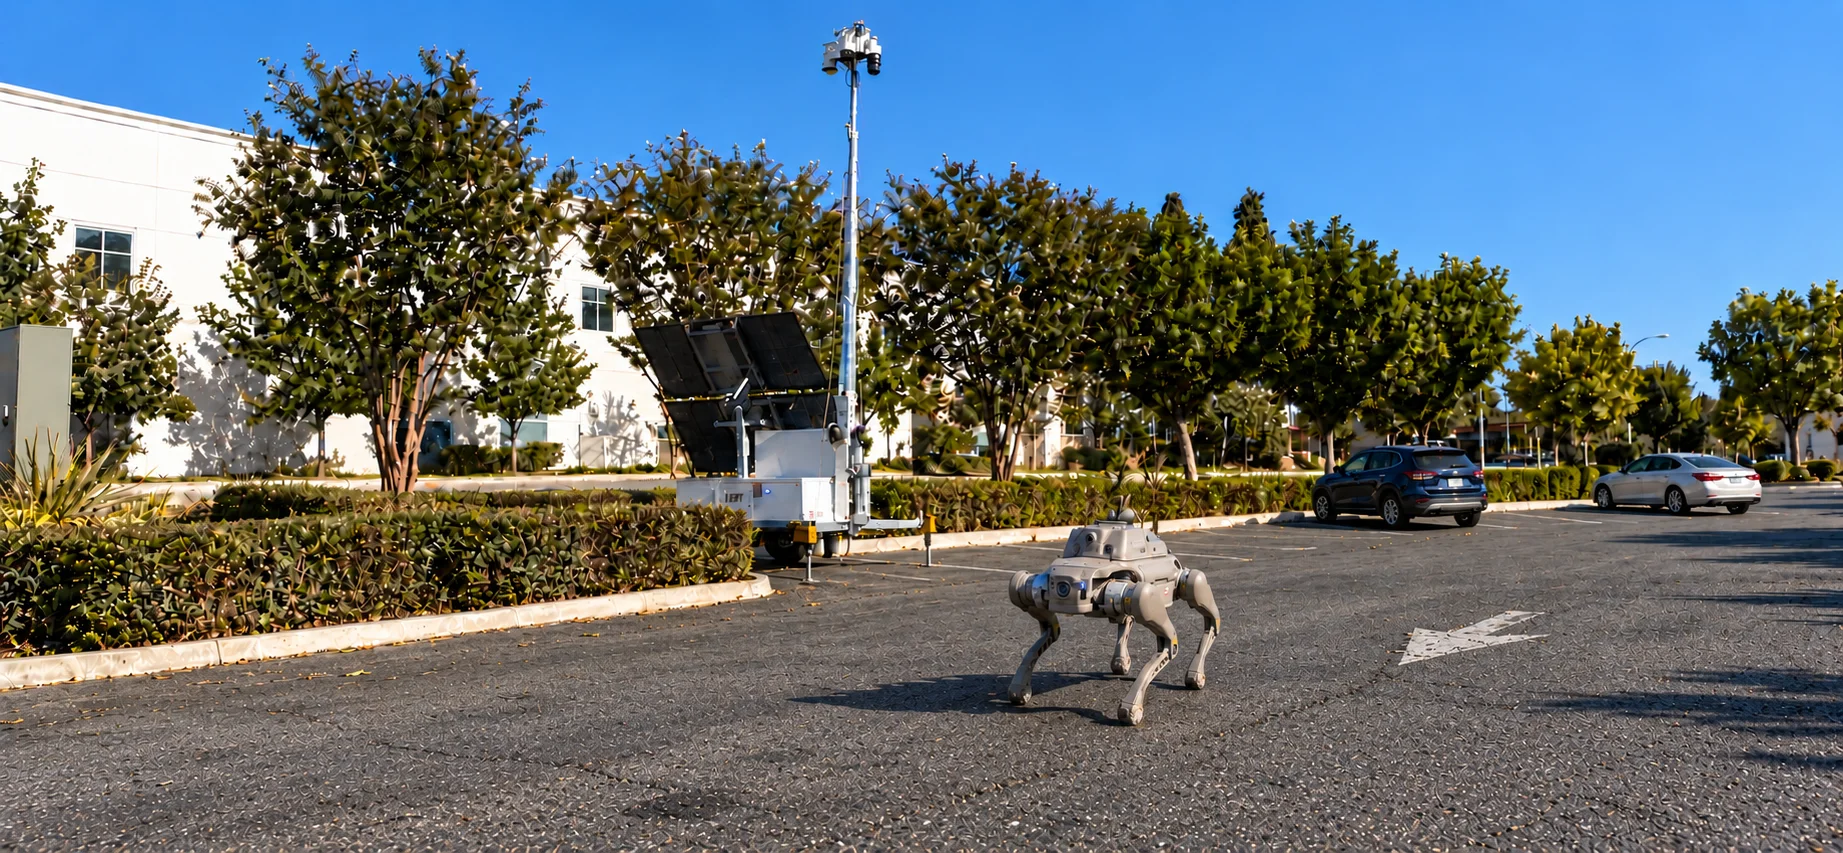
03 / FORCE 01
Select a legged or wheeled-leg configuration to suit the routes and surfaces at your site. Add sensing payloads to match the task.
Combined weight is calculated from the battery-equipped body plus the 518 g backpack, excluding mounting hardware and cables. Encoding capability is not a guaranteed network streaming rate. Final configuration determines endurance and available payload.
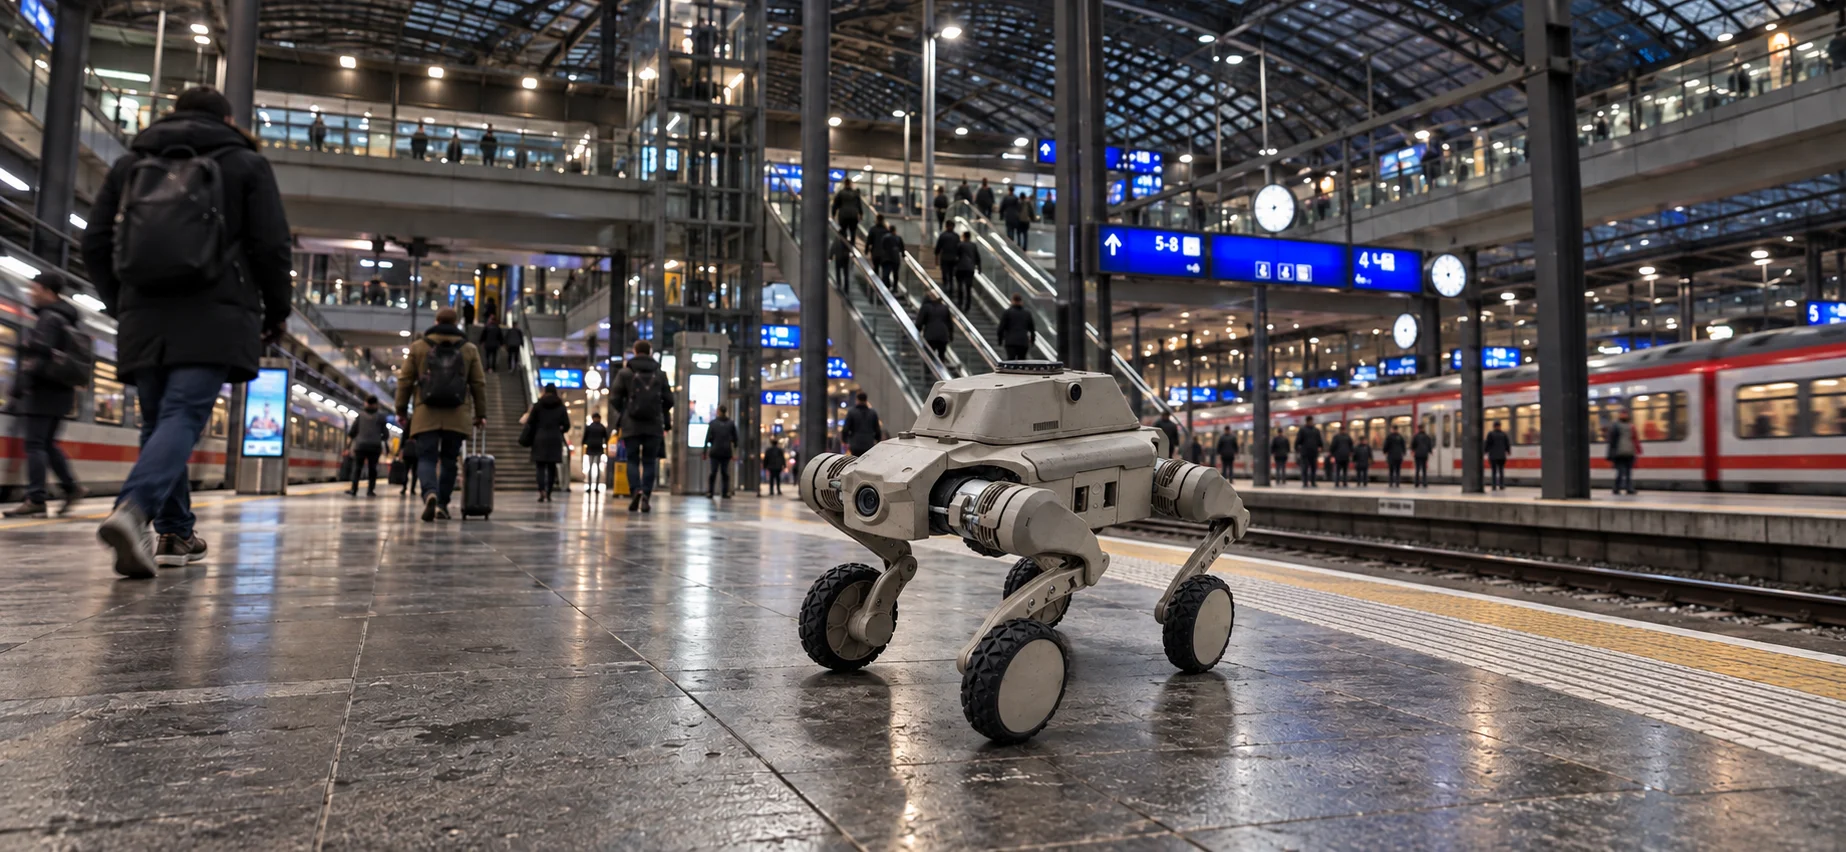
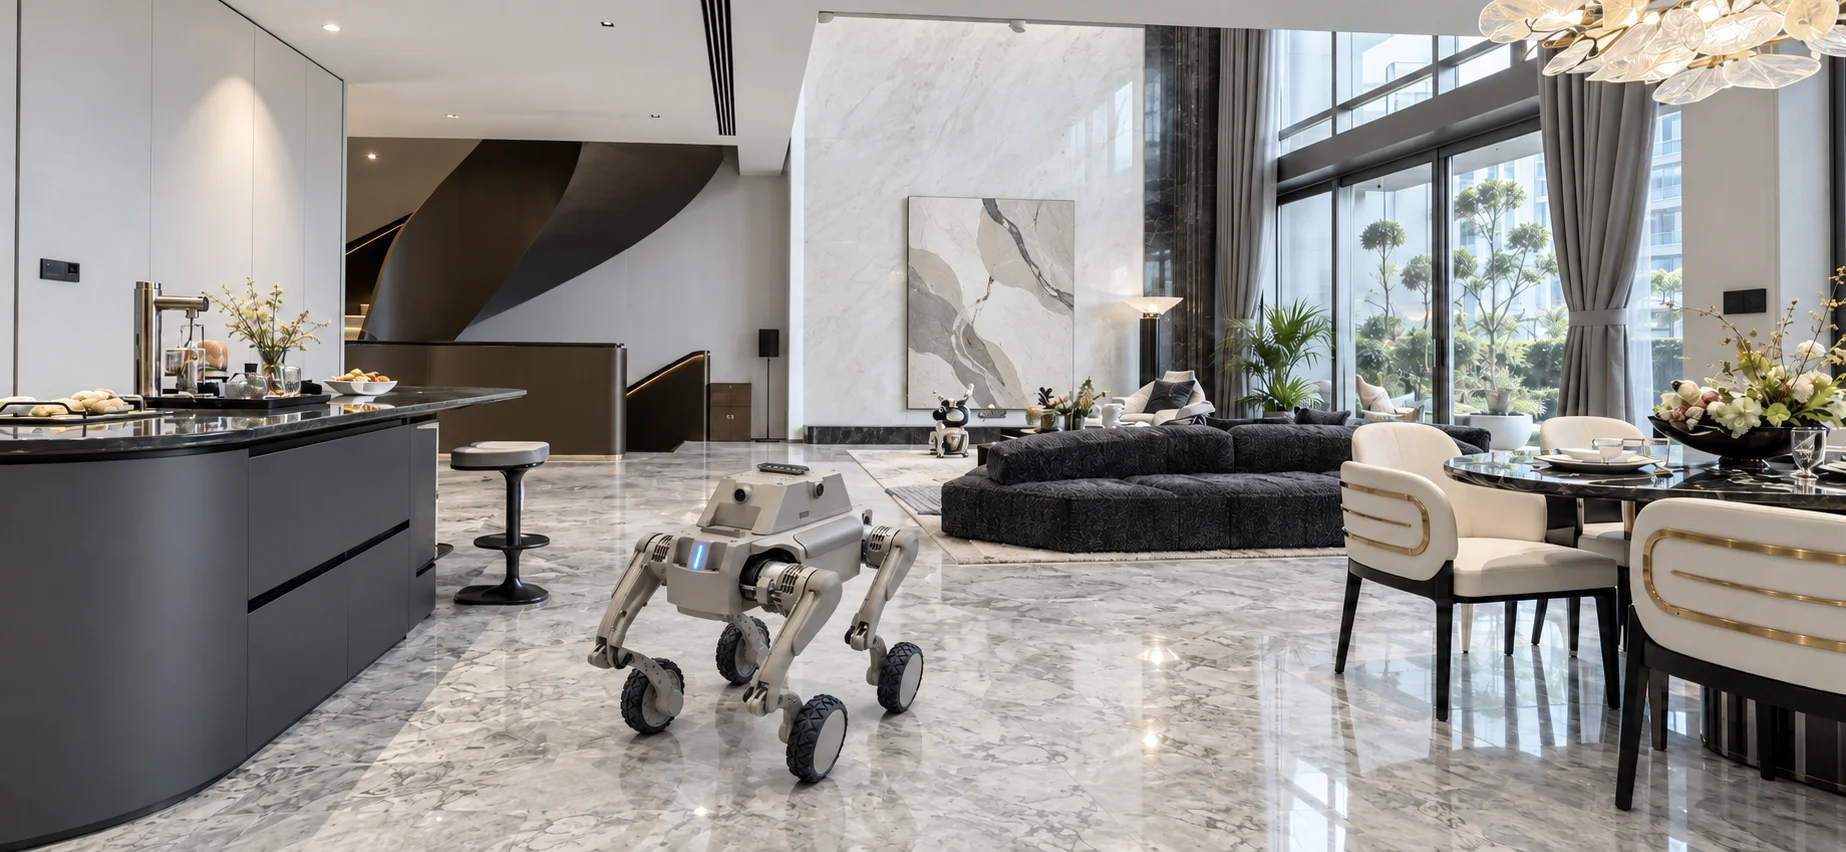
Application illustration. System configuration and suitability require project assessment.
Inspect public spaces, perimeters and key locations. Confirm unusual conditions remotely and bring live views back to the team.
Check gardens, community roads and underground car parks. Give residents and site teams a way to see the scene remotely.
Send a robot ahead into low-light, obstructed or difficult-to-access areas to assess conditions before people enter.
Check facility conditions and investigate alerts from a distance, reducing repeated journeys to dispersed sites.
Explore the other FORCE robot
FORCE 05PROJECT CONSIDERATIONS
Assess the operating environment, observation requirements and control workflow before defining the robotic system.
Review route surfaces, access constraints and observation points. Platform selection should follow the conditions of the site.
Define the information required by operators, the available connectivity and the procedure for ultra-range intervention.
Confirm sensing payloads, software interfaces and operating procedures as part of a project-specific configuration.
Contact
Tell us about your facility, patrol workload or inspection scenario, and we will match the right solution.